Precision Motion for Every Joint
6 actuator architectures from 10 to 150+ Nm — find the right module for your robot, validated and customized before mass production.
Inquiry Email
Send target torque/speed, protocol, quantity, and delivery location.
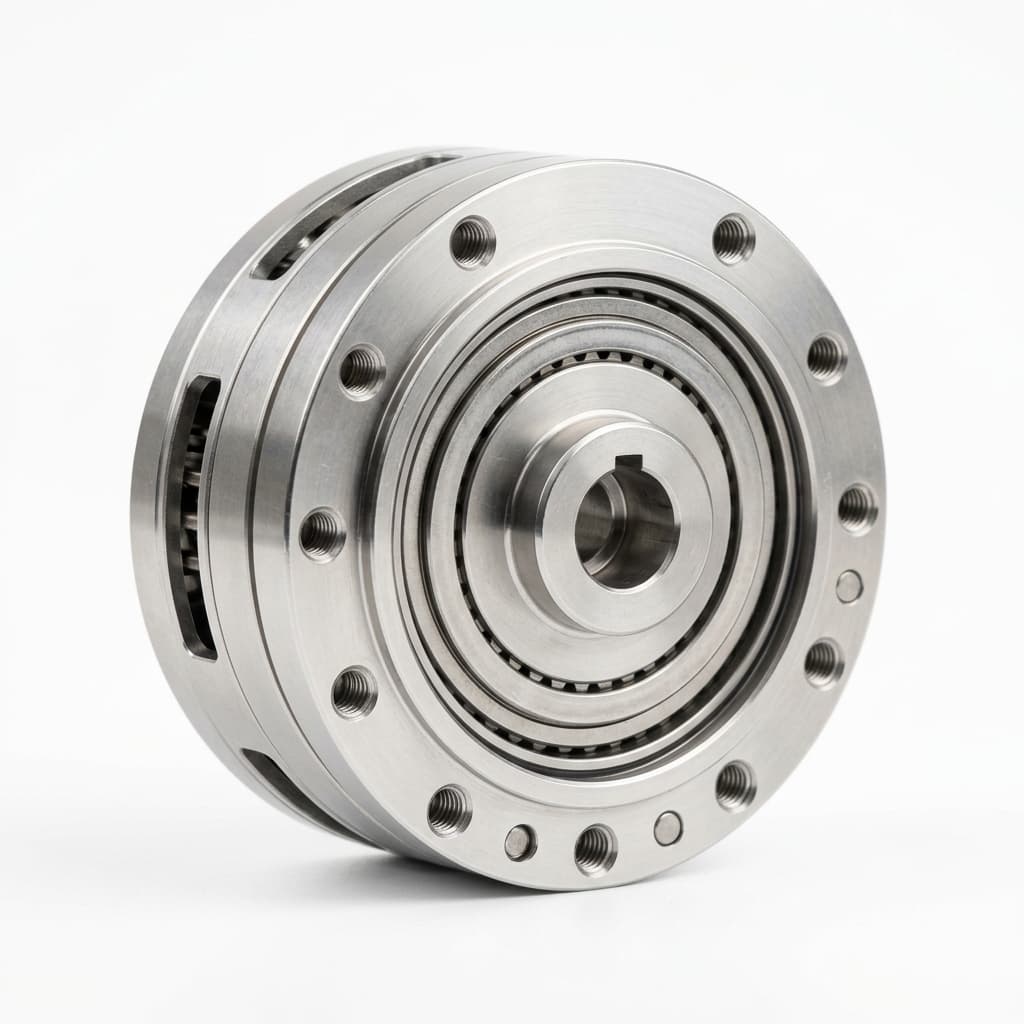
Product Architectures
Joint · QDD · SEA · Motor · Screw · Bus Module
Torque Coverage
From micro dexterous hands to humanoid legs
Sample Lead Time
Engineering samples to your bench fast
6 Actuator Families, One Engineering Partner
From hollow-shaft direct-drive to micro-precision ball screws — choose the architecture that matches your axis demand.
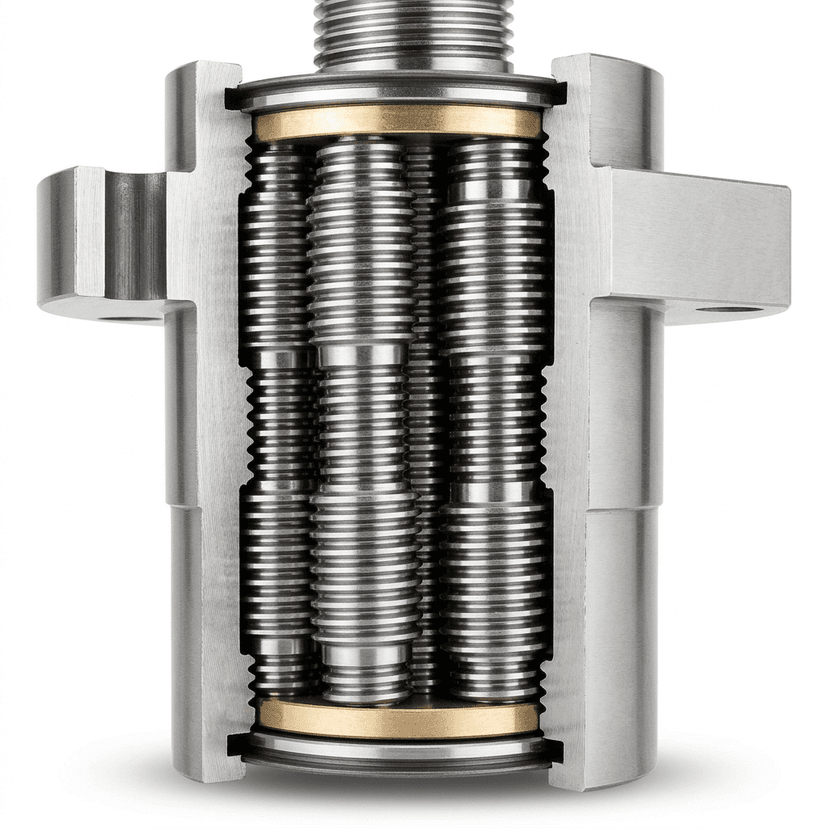
Inverted Planetary Roller Screw Actuator
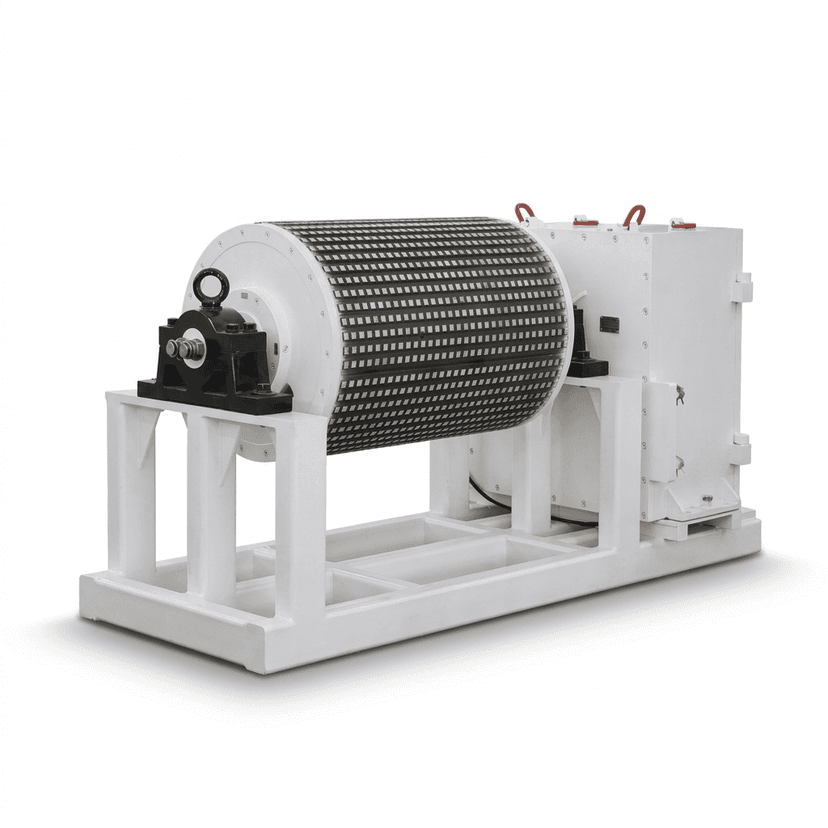
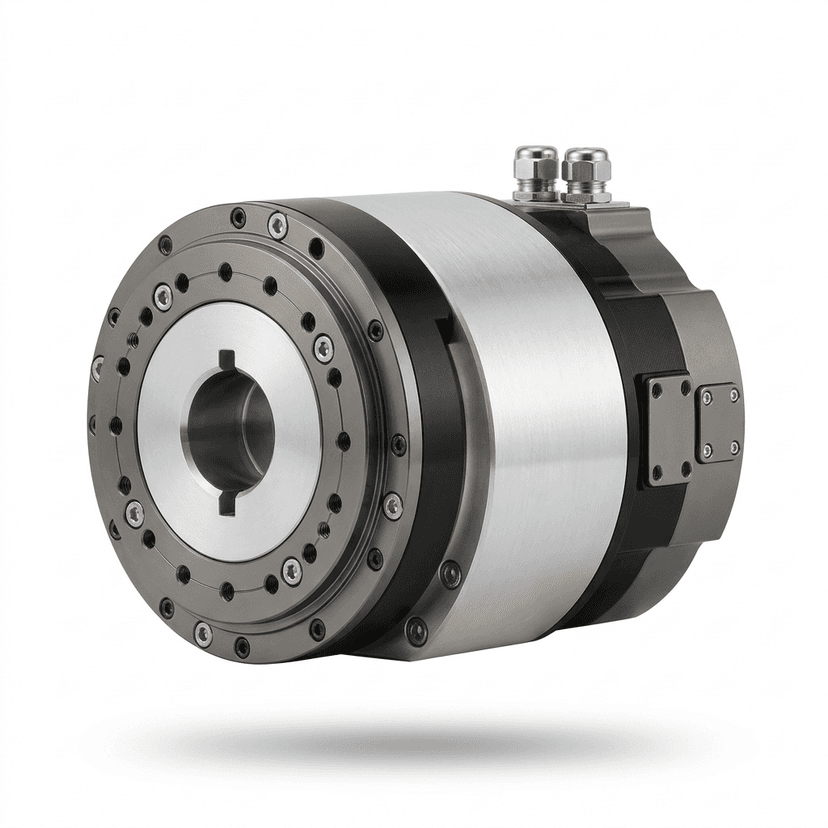
Quasi-Direct Drive (QDD) Hollow-Shaft Actuator
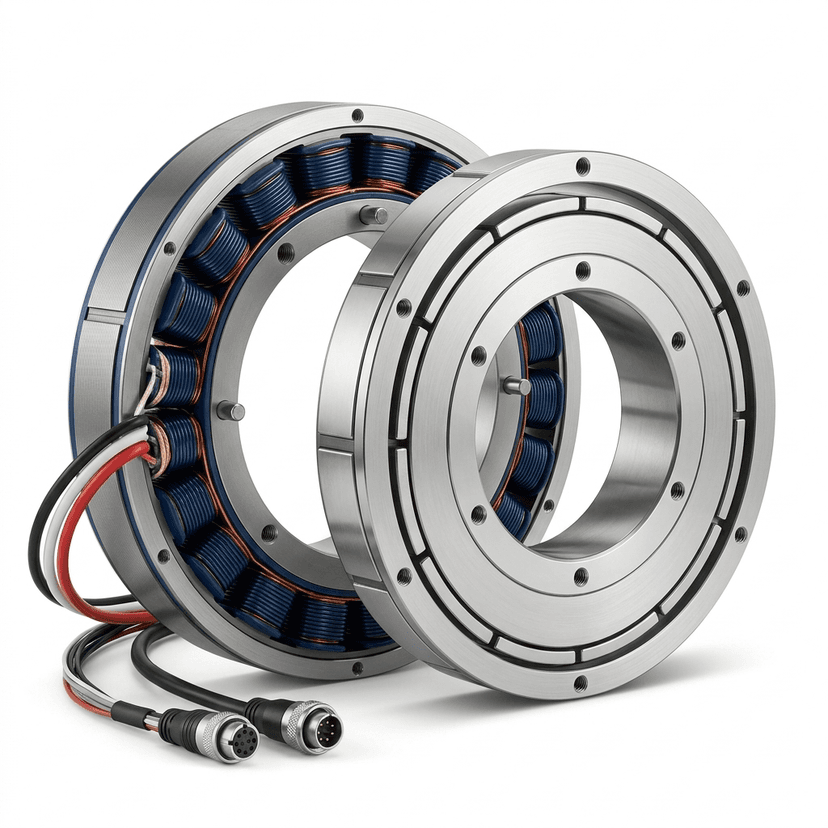
Frameless Torque Motor (Outrunner / Inrunner)
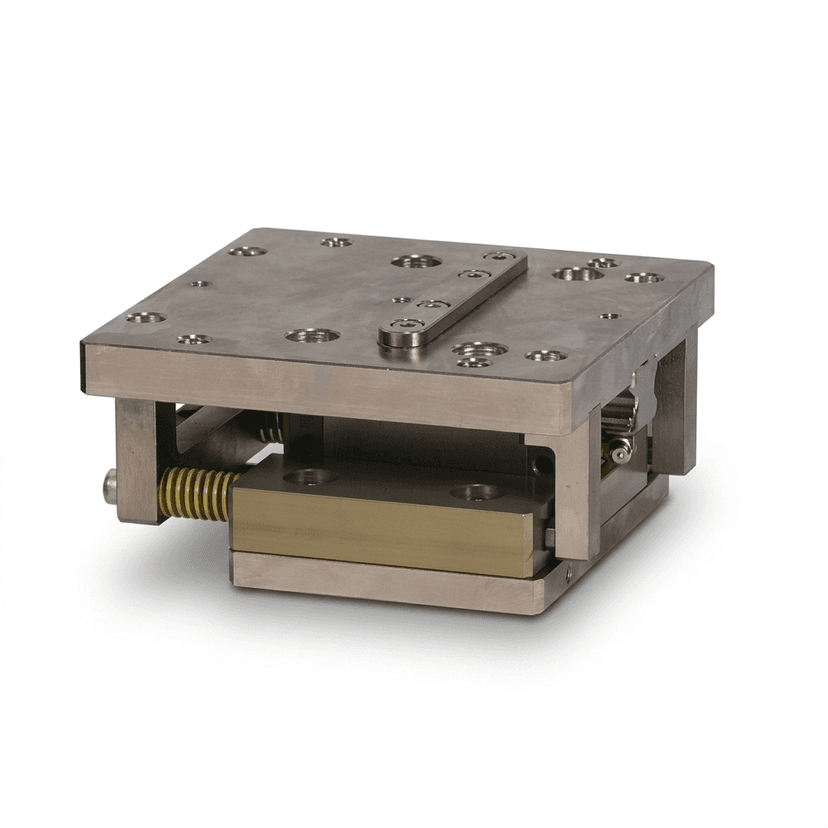
Series Elastic Actuator (SEA) Module
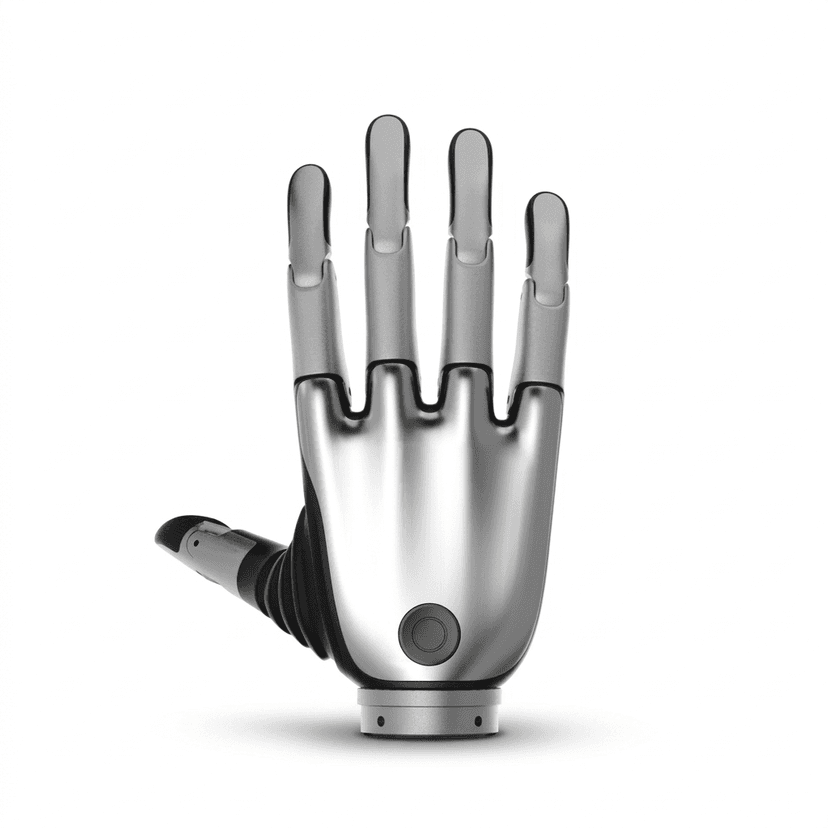
Micro Ball Screw for Dexterous Hands
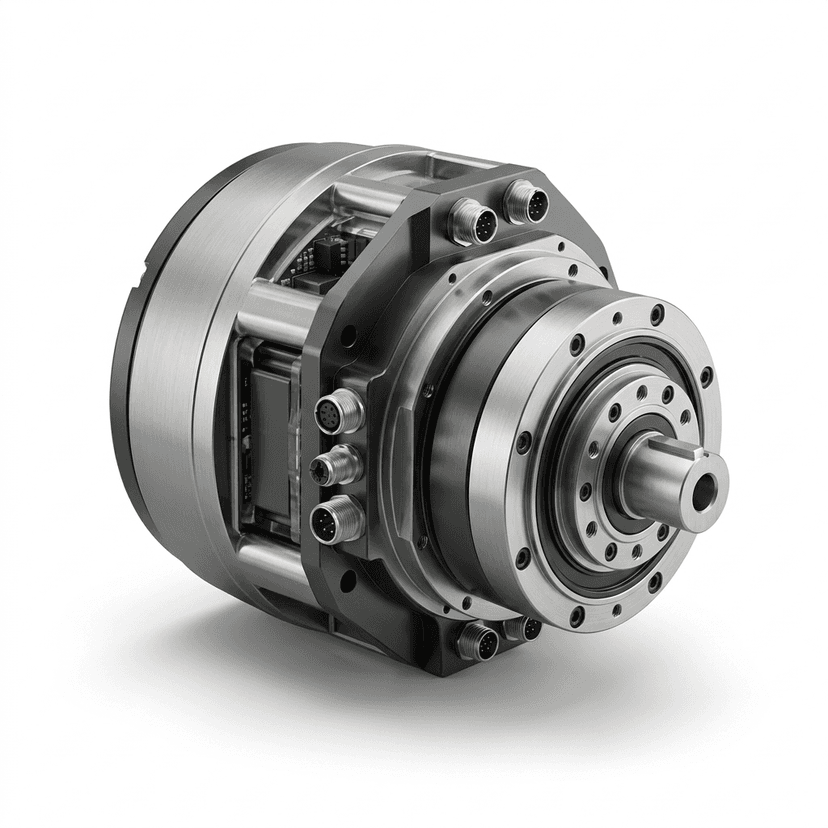
EtherCAT / CANopen Integrated Joint Module
Find the Right Architecture for Your Robot
Not sure which product family fits? Start from your application scenario — we recommend proven module combinations.
Skip the Middleman, Talk to the Engineers
How working directly with a vertically integrated Chinese factory compares to procuring from traditional branded distributors.
Sample Lead Time
faster
Traditional Brand
8–16 weeks
With Us
< 4 weeks
Customization
sample start
Traditional Brand
High MOQ, long NRE
With Us
Flexible, sample-first
Engineering Support
middlemen
Traditional Brand
Through distributors
With Us
Factory-direct engineers
Pricing
savings
Traditional Brand
Brand premium
With Us
Factory-direct pricing
Latest Engineering Guides
Practical buyer-side checklists, decision frameworks, and technical insights from our engineering team.
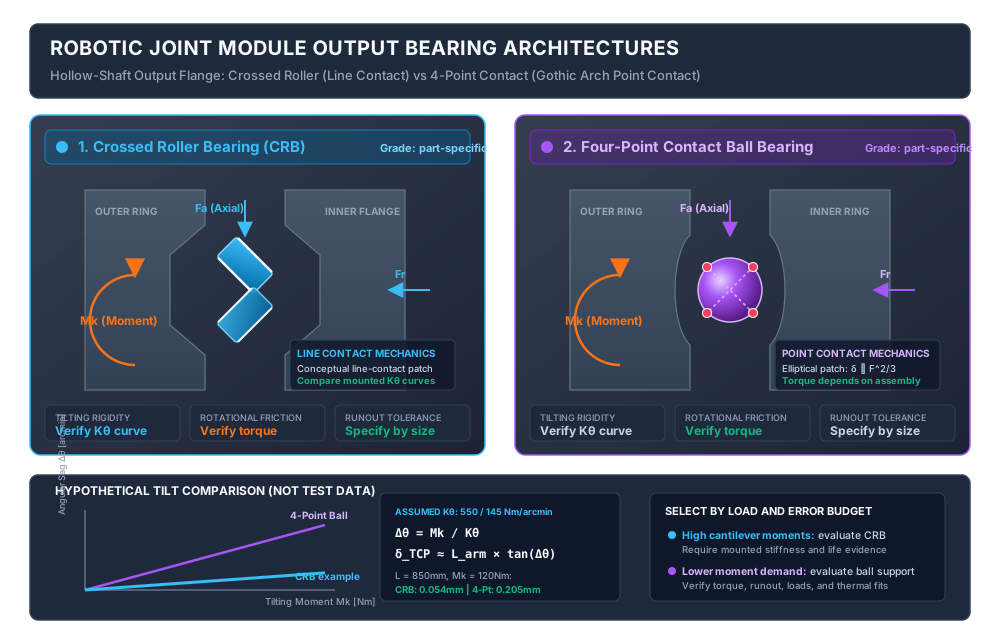
Crossed Roller vs Four-Point Contact Bearings in Hollow-Shaft Robotic Joint Modules: Tilting Moment Rigidity, Runout Tolerances, Preload, and Sourcing Guide
Compare crossed roller vs four-point contact bearings for robot joints. Evaluate tilting stiffness, runout, preload and thermal fits, then prepare your RFQ.
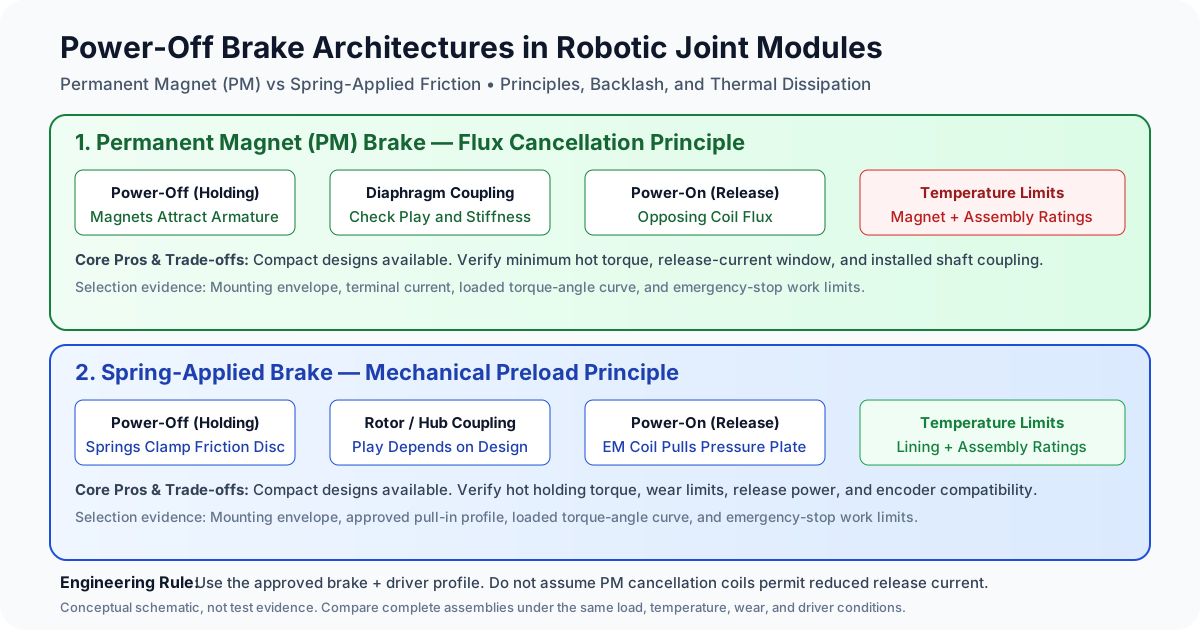
Permanent Magnet vs Spring-Applied Power-Off Brakes in Robotic Joint Modules: Holding Torque Density, Thermal Dissipation, Engagement Latency, and Fail-Safe Sourcing Guide
Compare permanent magnet vs spring-applied robot joint brakes for torque, heat, backlash and engagement time. Use the RFQ checklist to shortlist suppliers.
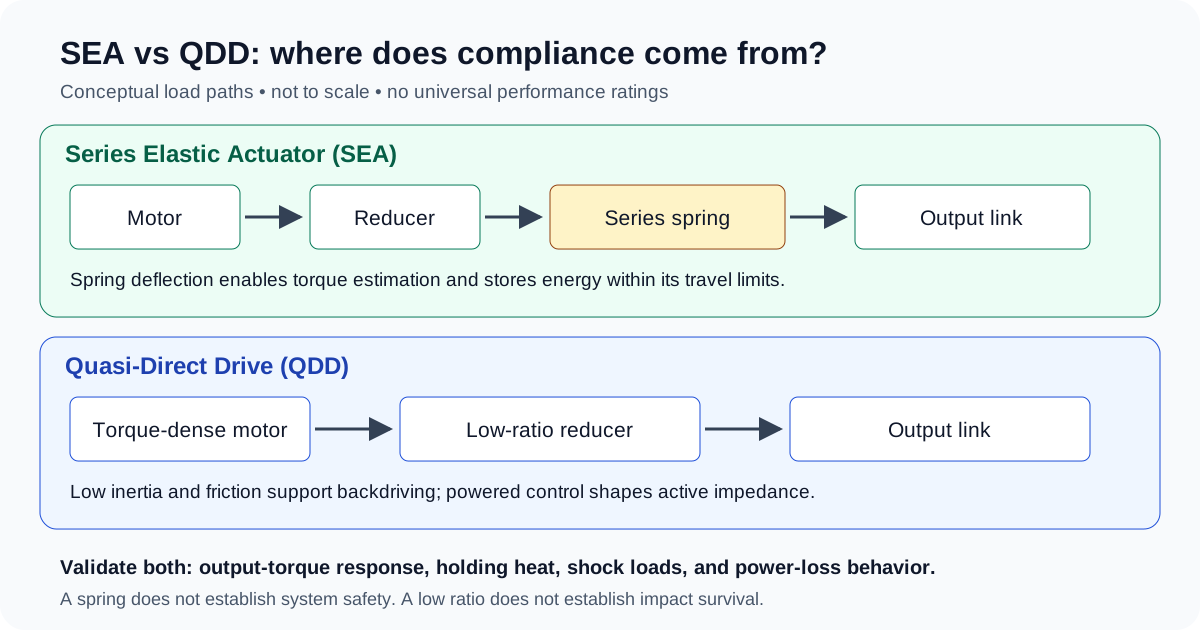
Series Elastic Actuators (SEA) vs Quasi-Direct Drive (QDD) Joint Modules: Force Bandwidth, Energy Recovery, and Humanoid Sourcing Guide
Compare SEA vs QDD robotic joint modules for force bandwidth, energy recovery, holding heat, and OEM sourcing. Use the checklist to prepare your actuator RFQ.
FAQ
Buyer Decision Support
Start Your RFQ
Share your specs and procurement timeline to receive engineering feedback and quotation support.
Inquiry Email
Send target torque/speed, protocol, quantity, and delivery location.