← Back to Solutions

Collaborative Robot Actuation

Actuator and control strategy guidance for cobot payload, interaction safety, and repeatability targets.
Target Buyer:Cobot integrators targeting safe interaction and reliable throughput.
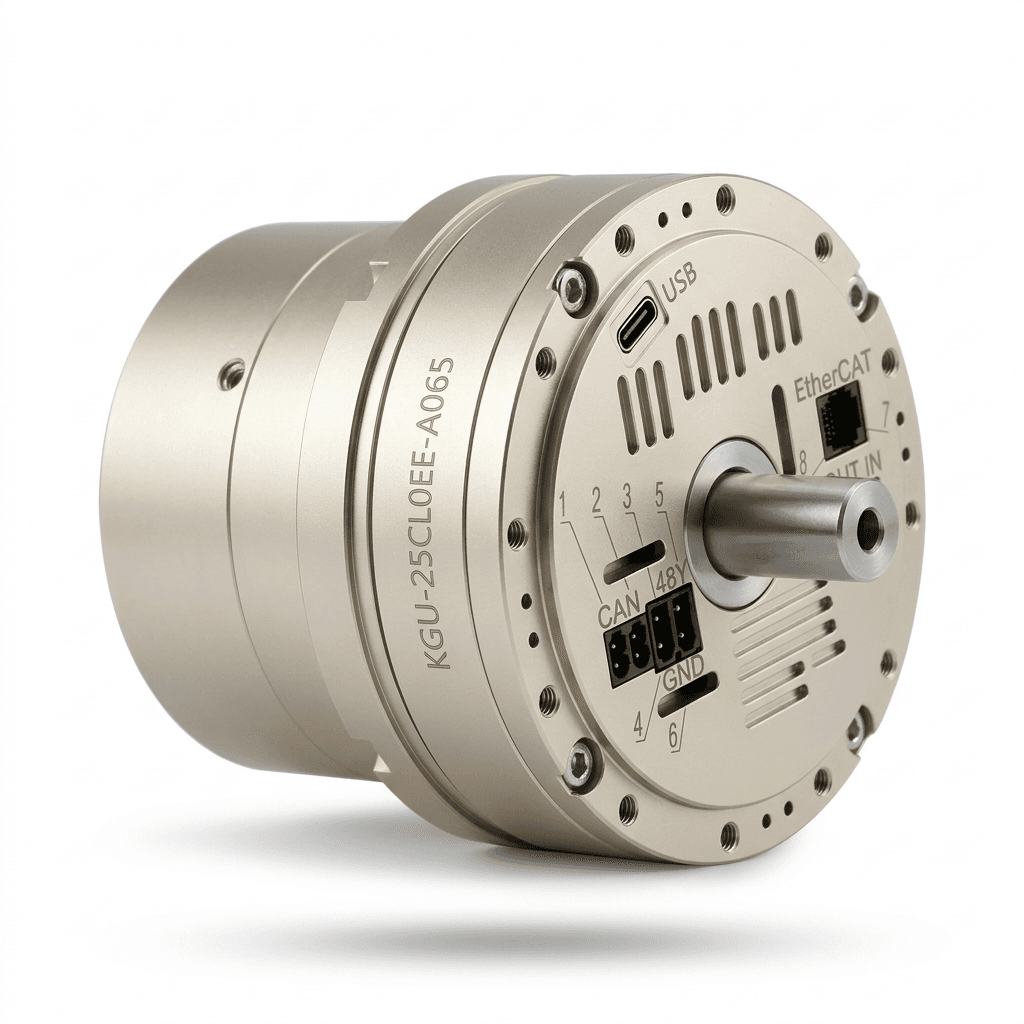
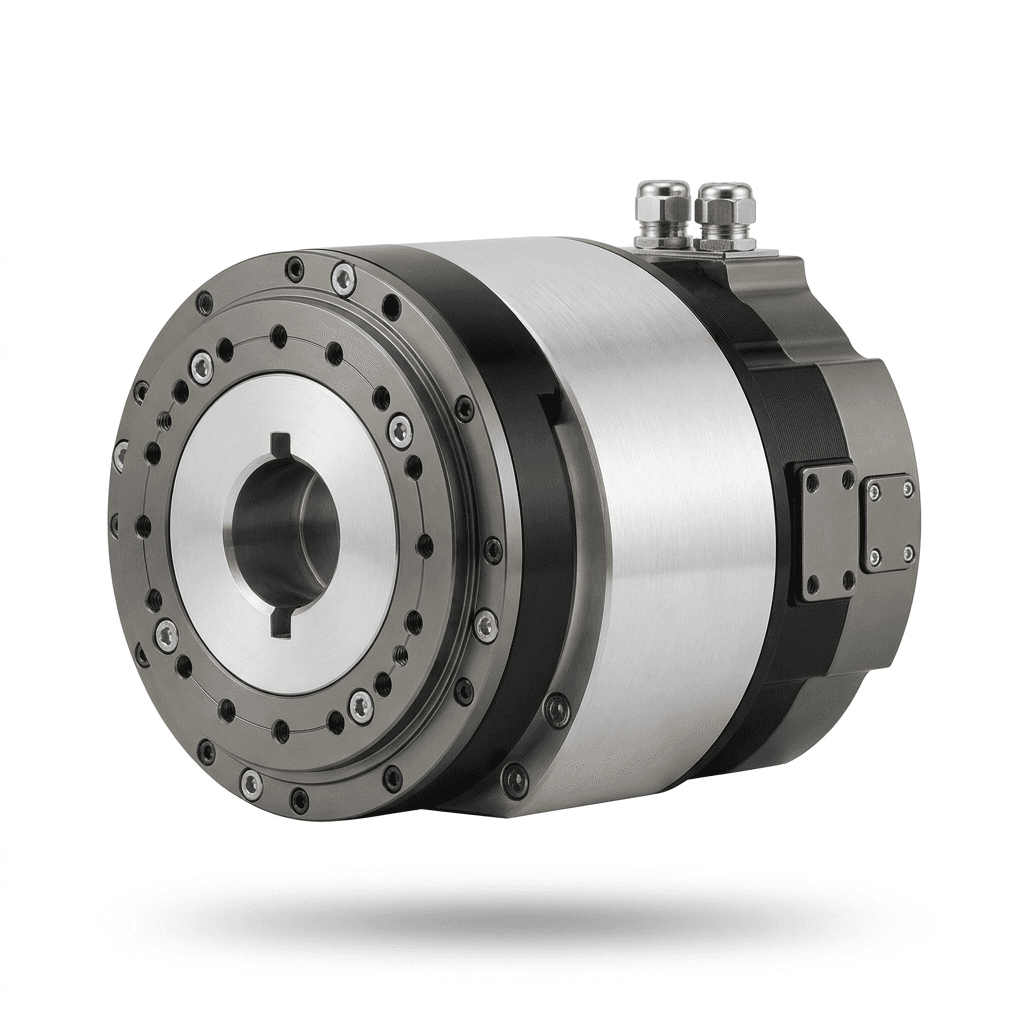
KGU modular collaborative robot joint integrated actuator with dual encoders (front view)

Solution Highlights

  • Force-aware actuation strategies
  • Repeatability and lifecycle considerations
  • Deployment support for production environments

Common Use Cases

  • Assembly cobots
  • Inspection cobots
  • Material handling assistants

Implementation Focus

  • Interaction force envelope
  • Repeatability under production duty
  • Preventive maintenance planning
  • Controller compatibility and commissioning burden control

Application Evaluation Matrix

Evaluation MetricTypical RangeBuyer Relevance
Cycle repeatability stabilityProject dependentDetermines long-term process capability and maintenance interval planning.
Payload derating at target duty cycleApplication-specific envelope definitionAvoids optimistic payload assumptions that reduce line throughput later.
Fieldbus and control-loop latency budgetDefined per controller and bus stackImpacts path smoothness, force limiting behavior, and tuning effort.
Preventive maintenance intervalHours/cycles target by workloadSupports realistic spare planning and production continuity.

RFQ Preparation Checklist

  1. Payload and cycle-time targets
  2. Safety/compliance expectations
  3. Controller and fieldbus stack
  4. Deployment region and compliance constraints

Risk and Mitigation

  • Lifecycle drift causing process variability: Set acceptance criteria for wear, backlash, and recalibration windows.
  • Force-limit tuning mismatch in real workcell scenarios: Validate contact and near-contact routines with representative tooling early.
  • Controller integration delays near deployment: Freeze communication stack and commissioning checklist before pilot install.

Recommended Products

KGU hollow-shaft collaborative robot arm joint actuator with internal cable passage
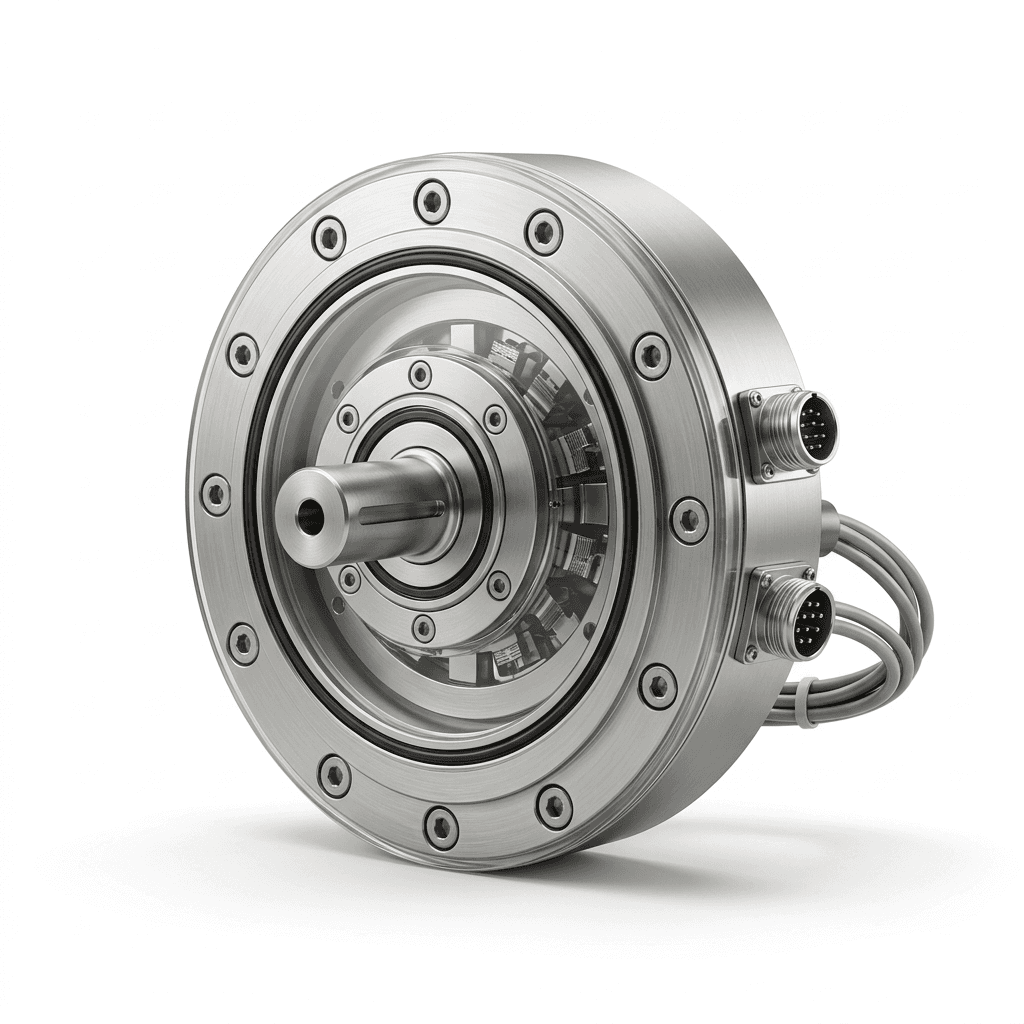
Ultra-thin pancake dynamic reaction torque sensor disc for cobot joint collision detection
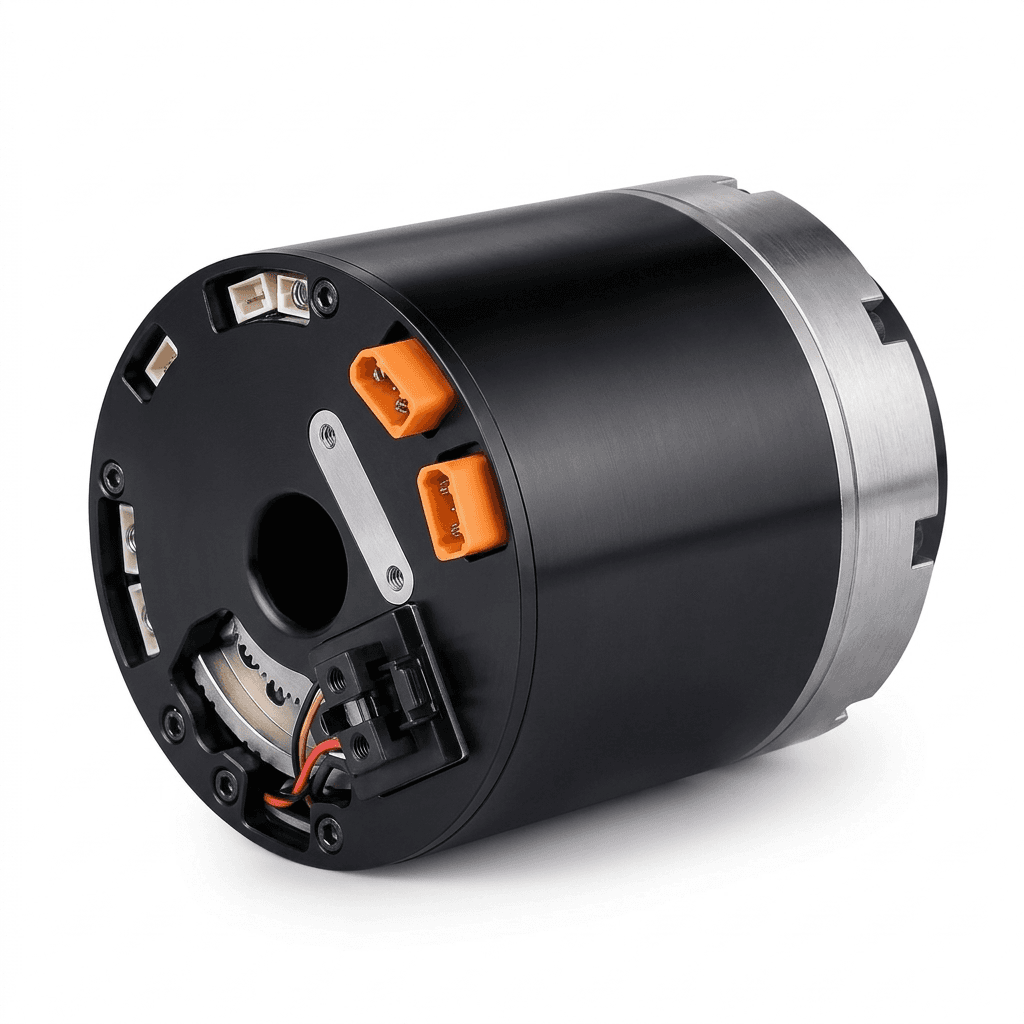
Low-power-consumption collaborative robot elbow joint unit with smooth harmonic gearing

Buyer FAQ

Can you support both sample and stable repeat supply?

Yes. We support sample validation and repeat supply planning for qualified models.

Can your team help define acceptance criteria for repeatability and wear?

Yes. We can co-define test metrics and decision thresholds tied to production objectives.

Do you support integration with CANopen or EtherCAT control environments?

Yes. Interface and commissioning scope can be aligned during RFQ and pilot planning.

Related Resources

Inquiry Email

[email protected]

Open email app

Send target torque/speed, protocol, quantity, and delivery location.

Instant Chat

+86 18857971991

Direct response from our engineering team.