← Back to Products

Frameless Torque Motor (Outrunner / Inrunner)

Frameless stator-rotor sets for compact direct-drive integration with low cogging and high motor constant targets.
Target Buyer:Mechanical and motor engineers embedding drive units into custom joint structures.
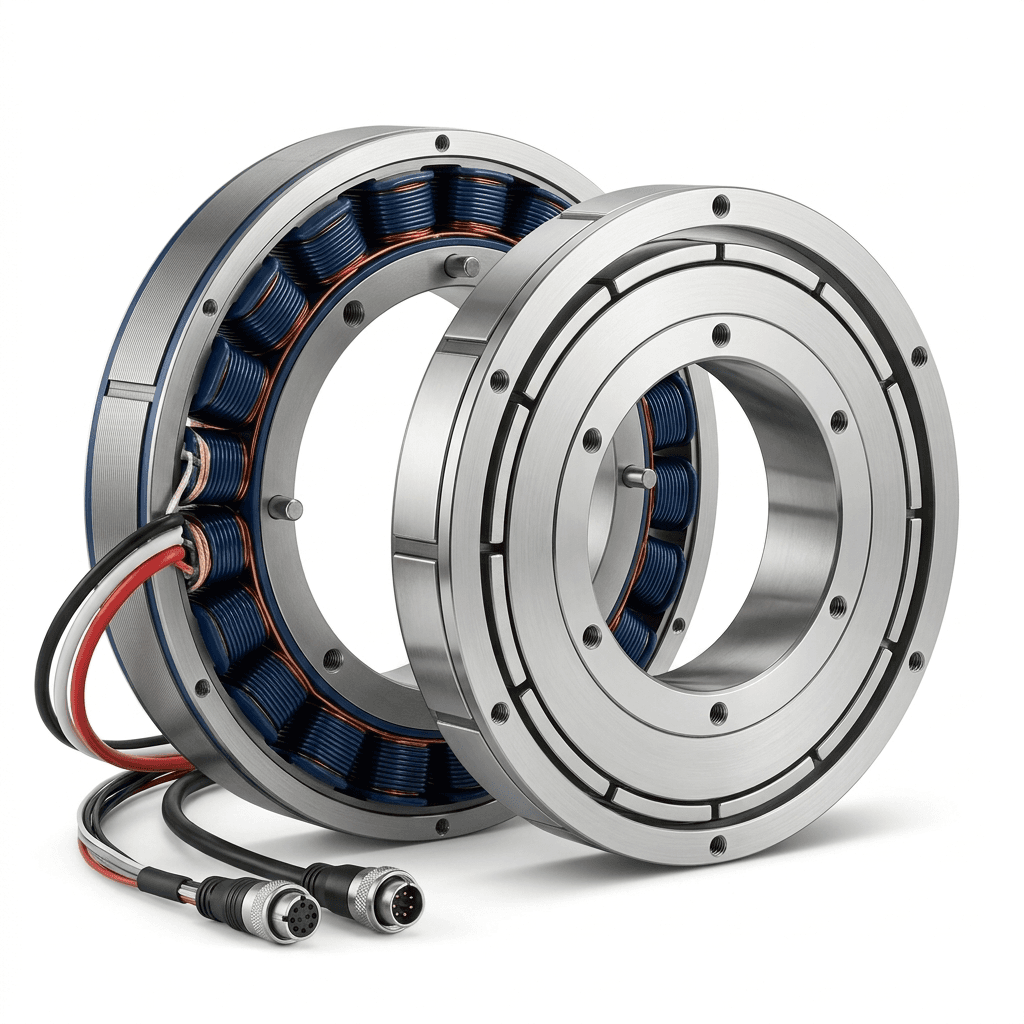
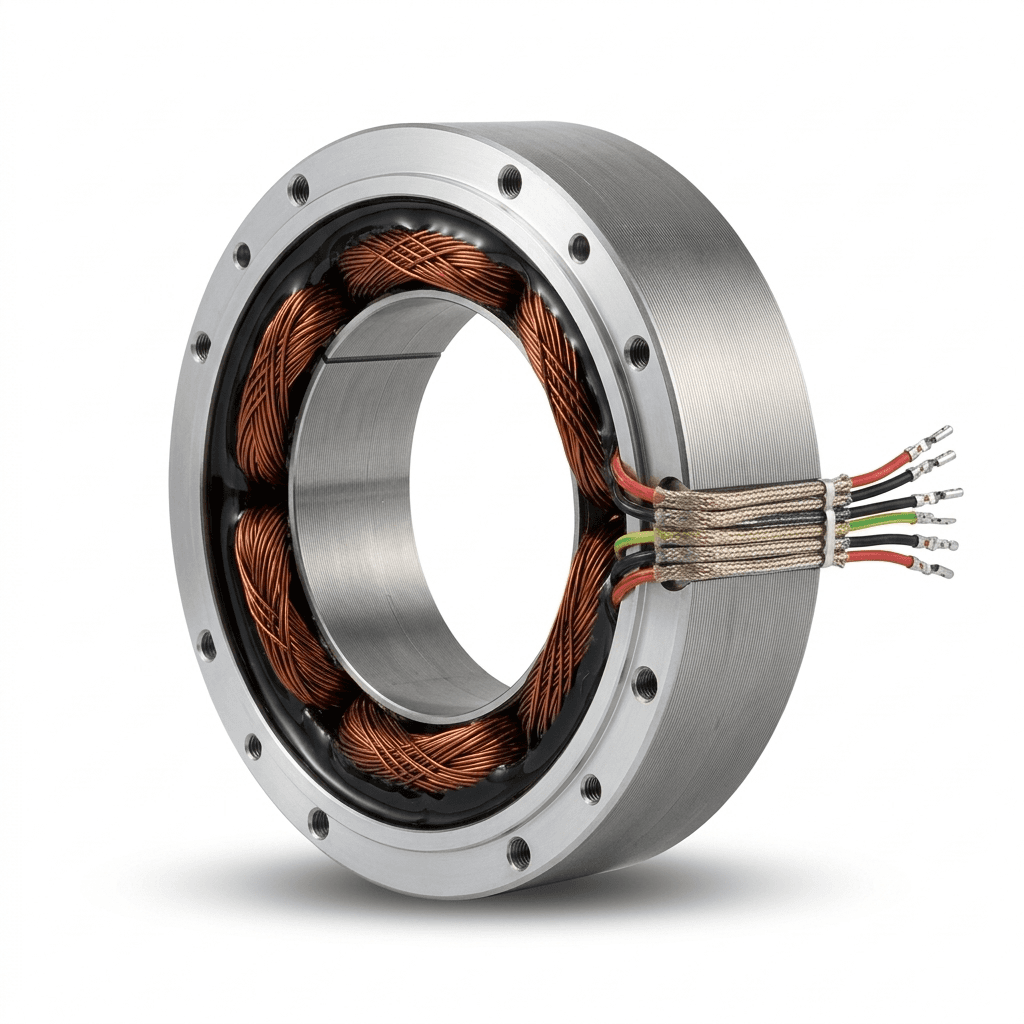
KMF direct-drive frameless torque motor stator and hollow rotor assembly

Inquiry Email

[email protected]

Open email app

Send target torque/speed, protocol, quantity, and delivery location.
Instant Chat

+86 18857971991

Direct response from our engineering team.

Capability Highlights

  • Outrunner and inrunner options for different torque-response goals
  • Direct housing integration without bulky servo shell
  • Supports winding and KV optimization by application

Typical Applications

  • Collaborative robot joints
  • Medical robotic articulation
  • Precision direct-drive gimbal and stage systems

Engineering Focus

  • Outrunner vs inrunner selection by inertia and bandwidth target
  • Thermal path design and housing integration controls
  • Cogging ripple control and low-speed smoothness requirements

Key Evaluation Matrix

MetricTypical RangeWhy It Matters
Stator outer diameter50-115 mm classesPrimary sizing input for torque constant and packaging.
Continuous torque class0.8-6+ Nm (by frame and cooling condition)Defines sustained operating capability under duty cycle.
Cogging behavior targetUltra-low ripple design preferenceImpacts precision motion quality in low-speed control.

Compliance and Trade Guidance

CE, RoHS, and REACH documentation support is available by project scope. HS classification should be treated as reference guidance only and must be confirmed by importer/broker based on destination rules and final product configuration.

  • Confirm required compliance document list before sample planning.
  • Include destination market and declaration scope in your RFQ message.
  • Review detailed guidance in Resources / Compliance.

Download Package Path

PackageWhen to RequestPurpose
DatasheetModel shortlist stageVerify electrical and performance envelope assumptions.
STEP / IGESMechanical integration reviewValidate envelope, mounting, and cable-routing compatibility.
Communication manualController and commissioning planningAlign protocol behavior, PDO mapping expectations, and diagnostics workflow.

Inquiry Email

[email protected]

Open email app

Send target torque/speed, protocol, quantity, and delivery location.
Instant Chat

+86 18857971991

Direct response from our engineering team.

RFQ Checklist

  1. Target continuous and peak torque per axis
  2. Voltage window and KV target
  3. Envelope constraints and thermal dissipation assumptions
  4. Encoder, cable, and assembly integration requirements

Risk Controls

  • Thermal saturation in compact enclosure: Review thermal path and continuous-load envelope before tooling lock.
  • Magnetic/assembly tolerance drift: Define rotor-stator concentricity and QA checkpoints in sample plan.

Product Gallery

Compact high-torque-density frameless BLDC torque motor kit for robot arm axes
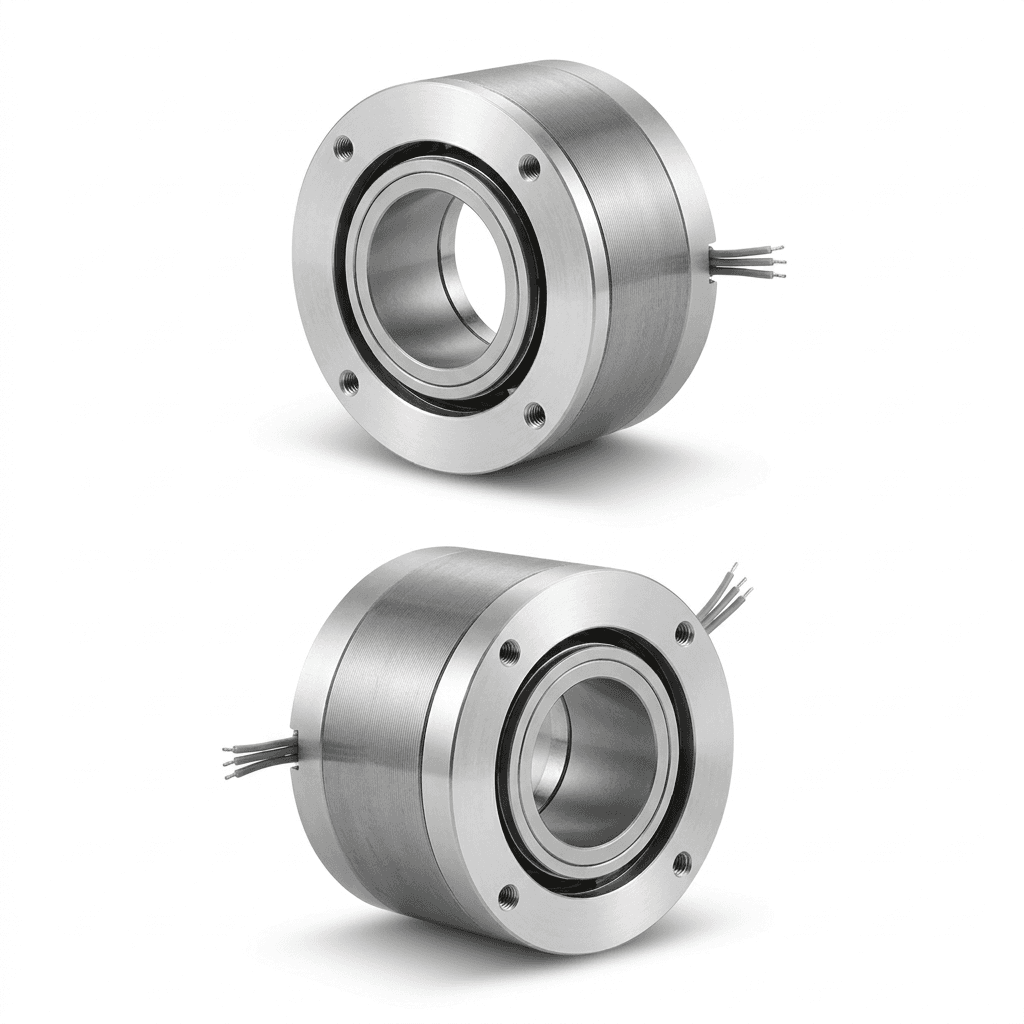
Large inner-diameter hollow-shaft frameless BLDC motor rotor and stator kit
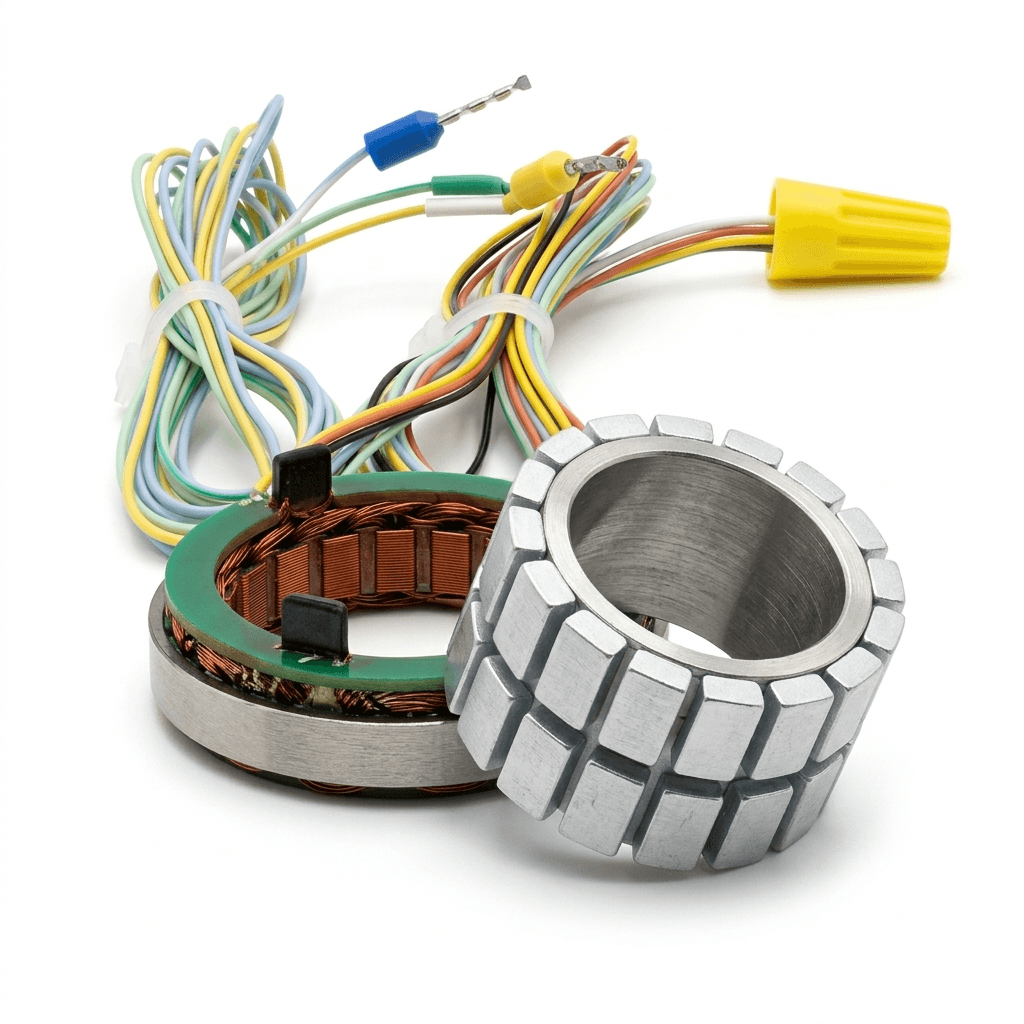
High-slot-fill precision copper windings detail of frameless servo motor stator

Buyer FAQ

Can you support both outrunner and inrunner frameless architectures?

Yes. We can support both structures and advise based on torque arm, inertia, and response requirements.

Can we request cogging and thermal test reports?

Yes. Test-report scope can be aligned during RFQ and sample validation.

Related Resources

Inquiry Email

[email protected]

Open email app

Send target torque/speed, protocol, quantity, and delivery location.
Instant Chat

+86 18857971991

Direct response from our engineering team.