← Back to Solutions

Medical & Rehabilitation Actuation

Force-control and compliance-oriented module strategy for medical and rehabilitation robotics workflows.
Target Buyer:Teams requiring high confidence in interaction behavior and validation traceability.
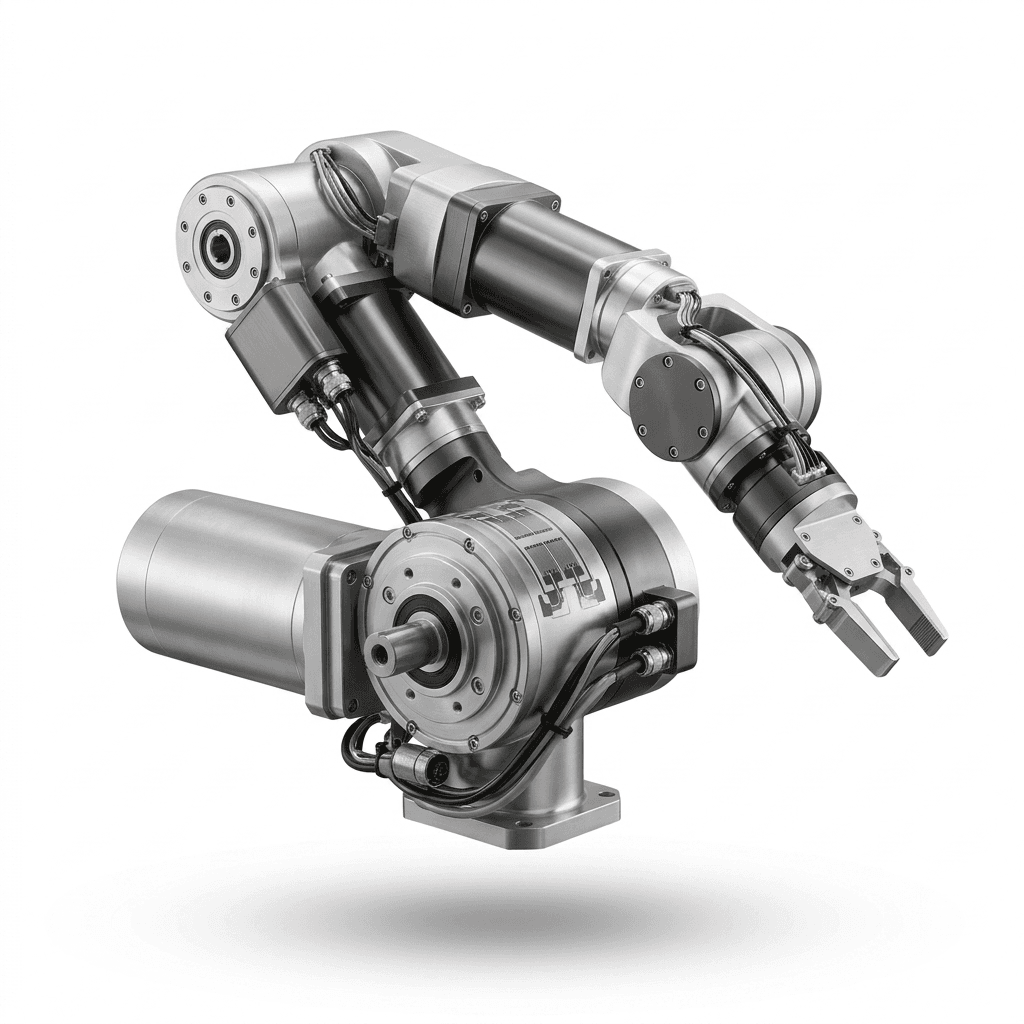
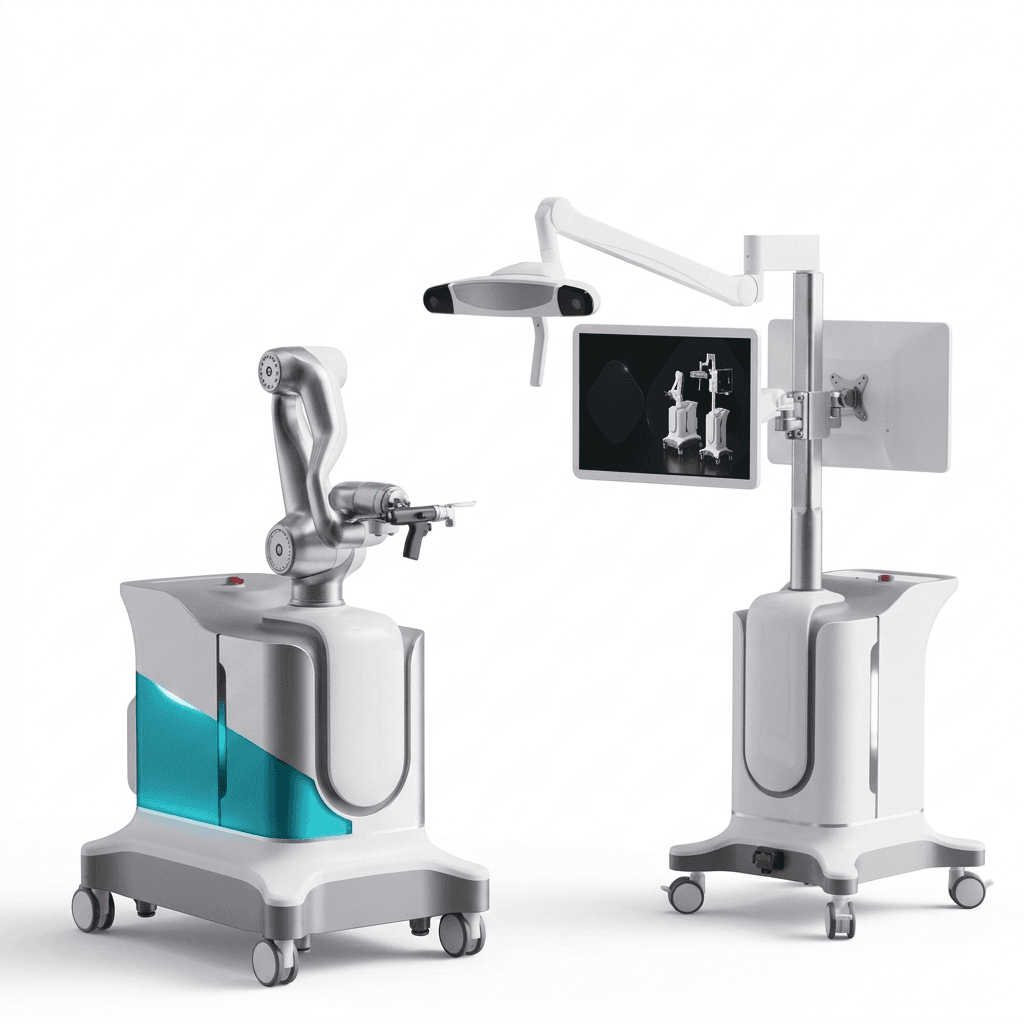
Orthopedic surgical robotic arm precision joint module with zero-backlash high stiffness

Solution Highlights

  • Interaction-safety-oriented control priorities
  • Traceable validation approach
  • Documentation-conscious project support

Common Use Cases

  • Rehab devices
  • Assistive robotics
  • Medical support mechanisms

Implementation Focus

  • Force-control stability under patient interaction
  • Reliability and documentation readiness
  • Customization boundary management
  • Traceable validation records for review and handoff

Application Evaluation Matrix

Evaluation MetricTypical RangeBuyer Relevance
Interaction safety confidenceValidation-ledEssential for risk-controlled deployment in human-interaction contexts.
Force/torque sensing fidelityDefined by use-case safety and control resolution targetsSupports predictable assistance behavior and repeatable therapy routines.
Noise and vibration envelopeProject-specific comfort thresholdDirectly impacts patient comfort and operator acceptance.
Documentation completeness cadenceMilestone-based release packageImproves auditability and reduces friction during internal quality review.

RFQ Preparation Checklist

  1. Force and safety envelope assumptions
  2. Control strategy and sensor requirements
  3. Validation and documentation expectations
  4. Pilot quantity and rollout plan

Risk and Mitigation

  • Insufficient interaction validation before rollout: Define staged validation gates before volume release.
  • Control drift between bench and patient-contact scenarios: Validate under representative load patterns, not only no-load tuning.
  • Late documentation gaps blocking qualification workflow: Agree document package scope and ownership at project kickoff stage.

Recommended Products

Medical rehabilitation exoskeleton rotary joint actuator with torque sensing and impedance control
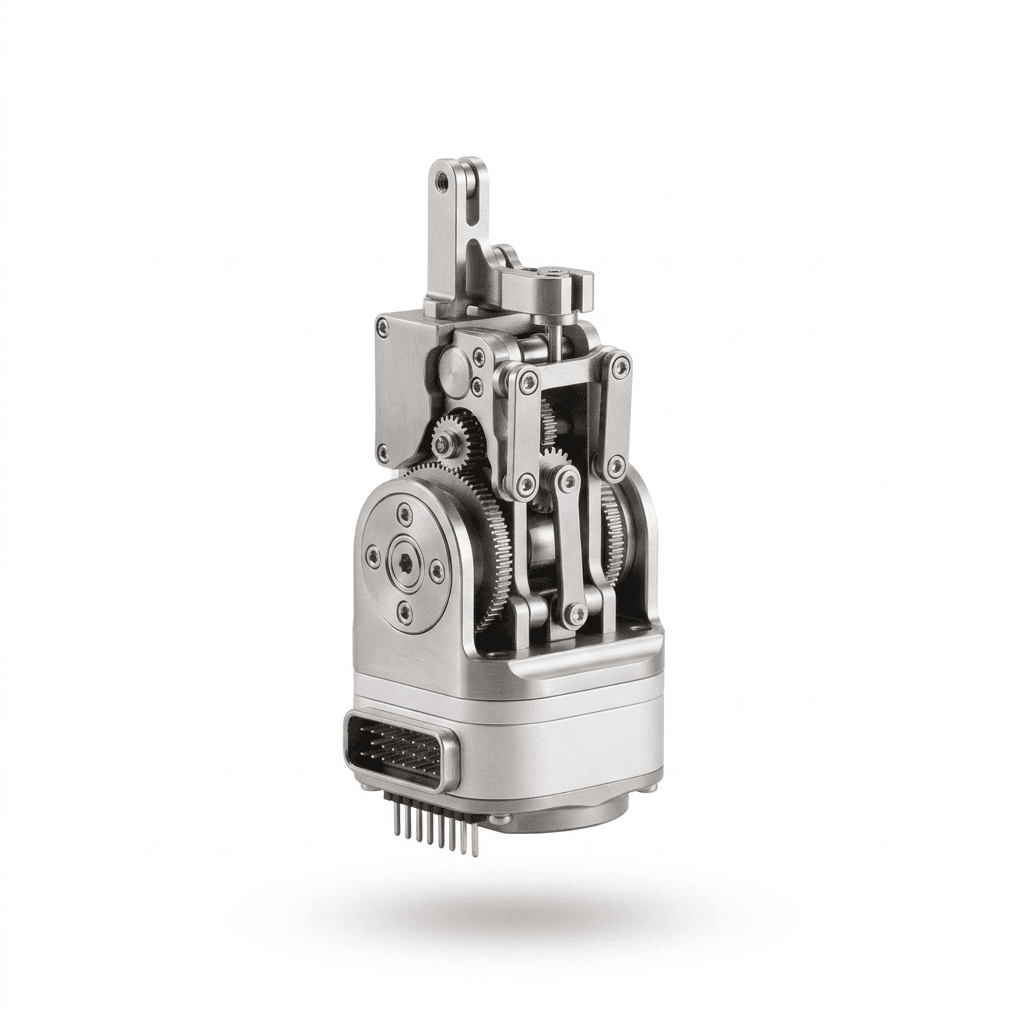
Miniature surgical robot manipulator wrist micro-actuator for endoscopic instruments
Wearable assistive exoskeleton compact servo joint motor with lightweight alloy chassis

Buyer FAQ

Do you support project-specific validation planning?

Yes, validation scope and checkpoints can be co-defined before mass production decisions.

Can we request a documentation package aligned with our internal review process?

Yes. Test evidence and process documentation scope can be defined in the RFQ and sample plan.

Do you support low-volume pilot phases before broader deployment?

Yes. We can support pilot builds with controlled revision tracking before scale-up decisions.

Related Resources

Inquiry Email

[email protected]

Open email app

Send target torque/speed, protocol, quantity, and delivery location.

Instant Chat

+86 18857971991

Direct response from our engineering team.