Solutions

Solutions & Applications

Select application scenarios to review recommended motion architectures, capability fit, and OEM support direction.

Each solution page is written for buyer-side decisions: what to validate first, where project risk usually appears, and what data should be included in the initial RFQ to avoid quote loops.

Application Selection Workflow

  1. Map your machine module and axis motion profile.
  2. Define performance acceptance criteria with measurable limits.
  3. Match solution architecture to control stack and thermal envelope.
  4. Before supplier comparison, run the actuator module key components checker to confirm motor, reducer/direct-drive path, encoder, brake, drive, thermal, harness, and housing evidence.
  5. Before commissioning actuator modules, review the integration guide for wiring, protocol, software, and acceptance gates.
  6. Freeze prototype validation gates before PO release.
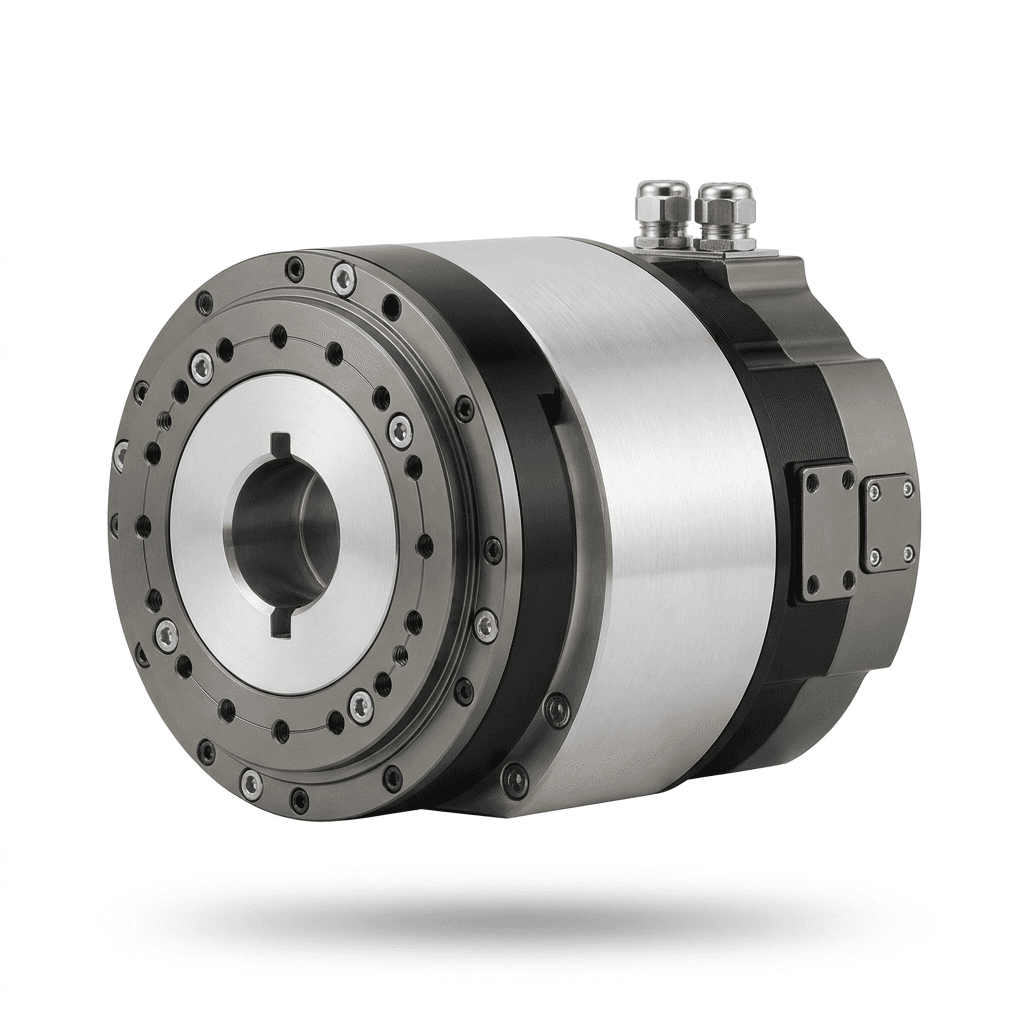
Humanoid bipedal robot 2-DOF pitch-yaw ankle joint actuator with dual high-response motors

Humanoid Joint Architecture

Joint module selection and integration guidance for humanoid upper-limb and lower-limb architectures.

Humanoid platform teams balancing performance, compactness, and reliability.

  • Duty-cycle-aware joint selection by axis function
  • Compact integration with cable-routing and serviceability constraints
  • Risk controls for impact, thermal rise, and wiring reliability events
View details
KGU modular collaborative robot joint integrated actuator with dual encoders (front view)

Collaborative Robot Actuation

Actuator and control strategy guidance for cobot payload, interaction safety, and repeatability targets.

Cobot integrators targeting safe interaction and reliable throughput.

  • Force-aware actuation strategies
  • Repeatability and lifecycle considerations
  • Deployment support for production environments
View details
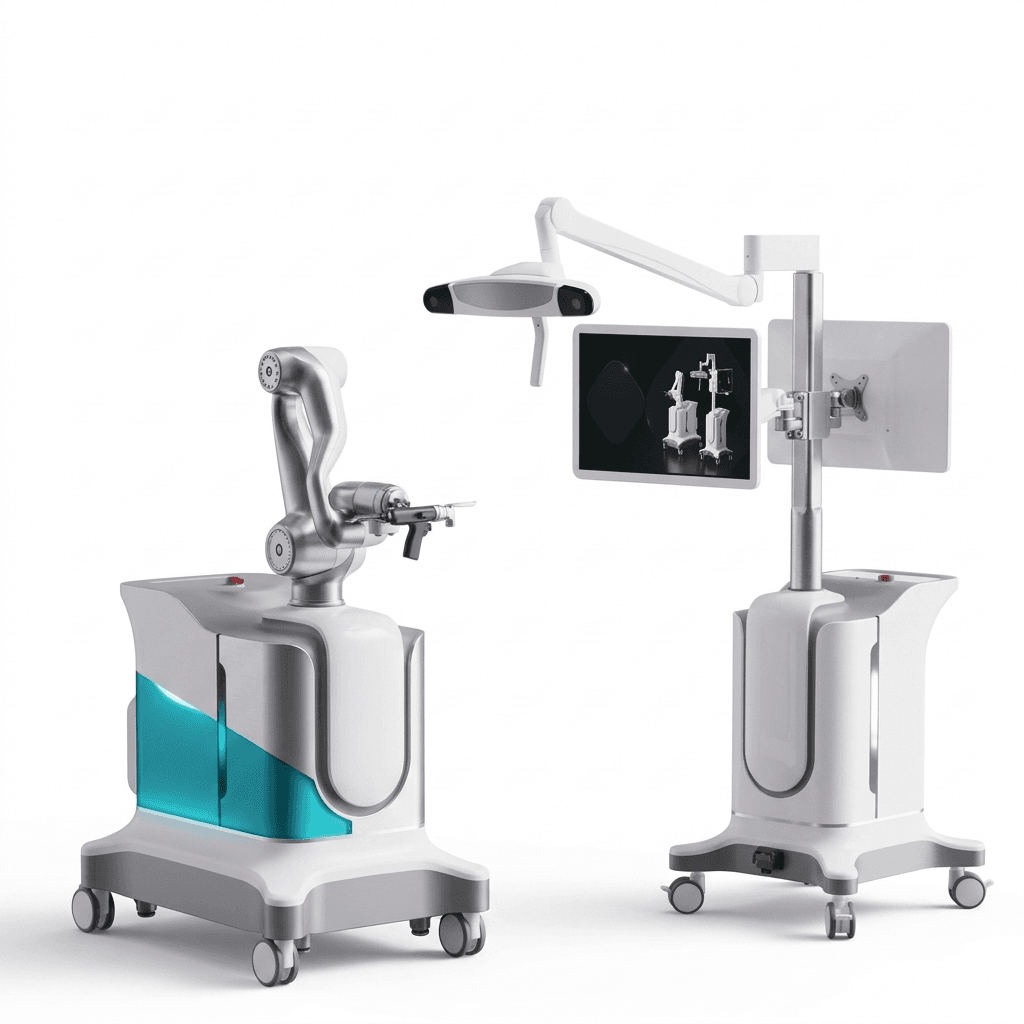
Orthopedic surgical robotic arm precision joint module with zero-backlash high stiffness

Medical & Rehabilitation Actuation

Force-control and compliance-oriented module strategy for medical and rehabilitation robotics workflows.

Teams requiring high confidence in interaction behavior and validation traceability.

  • Interaction-safety-oriented control priorities
  • Traceable validation approach
  • Documentation-conscious project support
View details
Solution Comparison Snapshot

SolutionPrimary Buyer FocusKey MetricWhy It Matters
Humanoid Joint ArchitectureHumanoid platform teams balancing performance, compactness, and reliability.Axis-level fit confidence: Per-axis validationPrevents late-stage redesign in full-body integration.
Collaborative Robot ActuationCobot integrators targeting safe interaction and reliable throughput.Cycle repeatability stability: Project dependentDetermines long-term process capability and maintenance interval planning.
Medical & Rehabilitation ActuationTeams requiring high confidence in interaction behavior and validation traceability.Interaction safety confidence: Validation-ledEssential for risk-controlled deployment in human-interaction contexts.

Scenario Validation Data Pack

Use this checklist to request comparable evidence across multiple suppliers before sample PO.

Data BlockWhat to RequestWhy It Matters
Axis Duty ProfileTorque-speed cycle with thermal assumptionsPrevents oversizing or unstable thermal behavior.
Integration BoundarySTEP/IGES fit notes, connector and routing constraintsAvoids late-stage mechanical and harness conflicts.
Validation MethodBench conditions, sample size, and pass/fail thresholdsEnsures supplier claims are comparable and auditable.

Buyer-Side Decision Rule for Solution Pages

  1. Pick one scenario and define measurable acceptance targets.
  2. Compare at least two actuator architectures using the same test context.
  3. Freeze integration and validation checkpoints before commercial negotiation.
  4. Use Contact/RFQ with attached checklist to shorten review cycles.

Inquiry Email

[email protected]

Open email app

Send target torque/speed, protocol, quantity, and delivery location.

Instant Chat

+86 18857971991

Direct response from our engineering team.