Products

Product Portfolio

Robotic joint module categories for industrial OEM sourcing, from precision harmonic modules to compliant and integrated bus-connected actuator architectures.

Use this page as a pre-RFQ navigator: pick the product family, capture the correct engineering inputs, and move directly to sample validation criteria that buyers can approve.

How to Select the Right Path

  1. Define required torque at target speed and acceleration profile.
  2. Confirm mechanical interface constraints (shaft, flange, connector).
  3. Choose control architecture (open-loop, closed-loop, driver stack).
  4. For BOM ownership and component evidence, run the Actuator Module Key Components Checker before comparing supplier quotes.
  5. For wiring, protocol, software, and commissioning gates, review Actuator Module Integration Guide before sample PO.
  6. Set sample acceptance criteria before quotation freeze.
  7. For system-integration planning, review Solutions & Applications before RFQ.
  8. For customization governance and validation checkpoints, review OEM Capabilities.
  9. For compliance references, HS guidance, and download package strategy, review Resources / Compliance.
  10. For pricing, budget bands, and TCO breakdown, read the Actuator Module Price & Cost Guide.
  11. Evaluate and match with the right manufacturing partner using our Supplier & Manufacturer Qualification Matcher.
  12. For direct technical-commercial alignment, contact our engineering team via Contact / RFQ before RFQ lock.
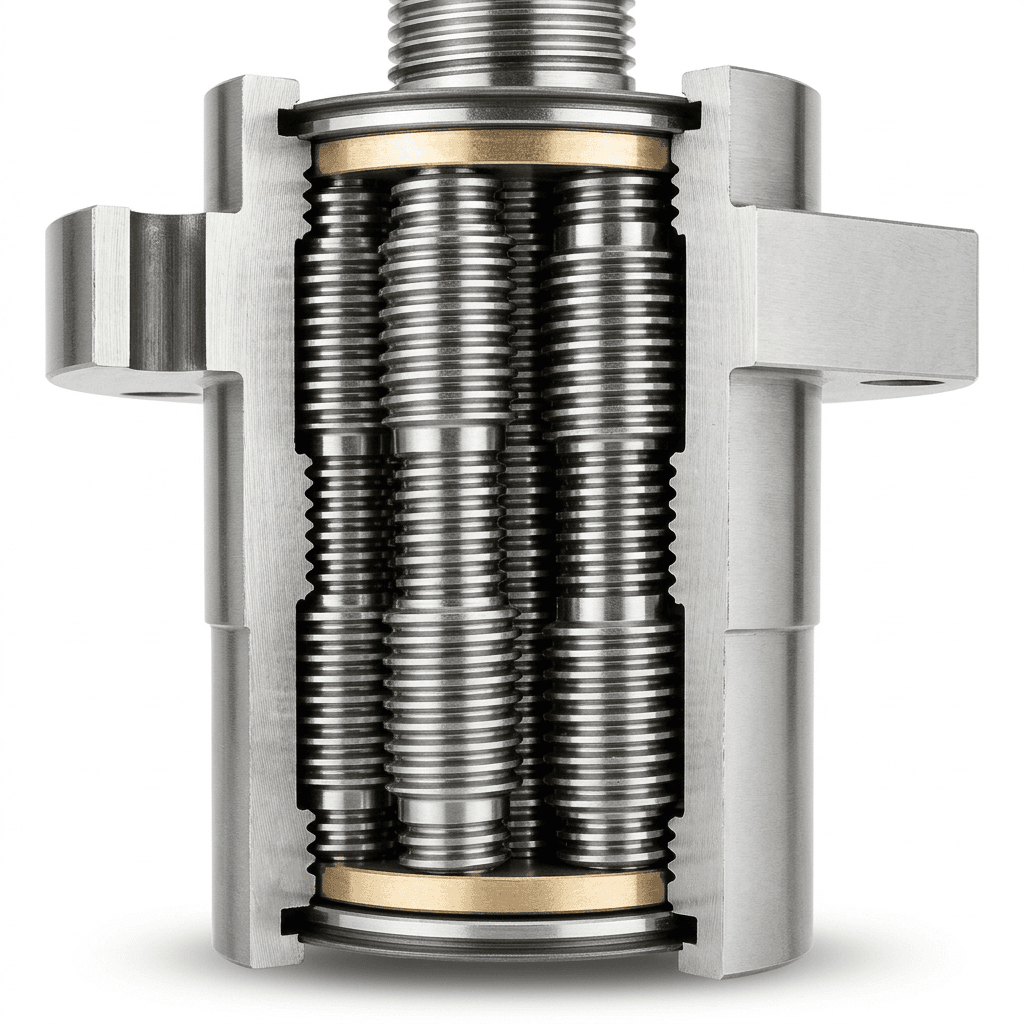
Heavy-duty planetary roller screw servo electric cylinder actuator for high-load robotic articulation

Inverted Planetary Roller Screw Actuator

Compact high-load linear actuator architecture for humanoid leg and arm joints where axial space is limited.

Humanoid hardware teams needing high-force linear drive in constrained envelopes.

  • High axial load capability with compact packaging strategy
  • Supports custom stroke, lead, and preload preferences
  • Suitable for shock-prone dynamic motion scenarios
View details
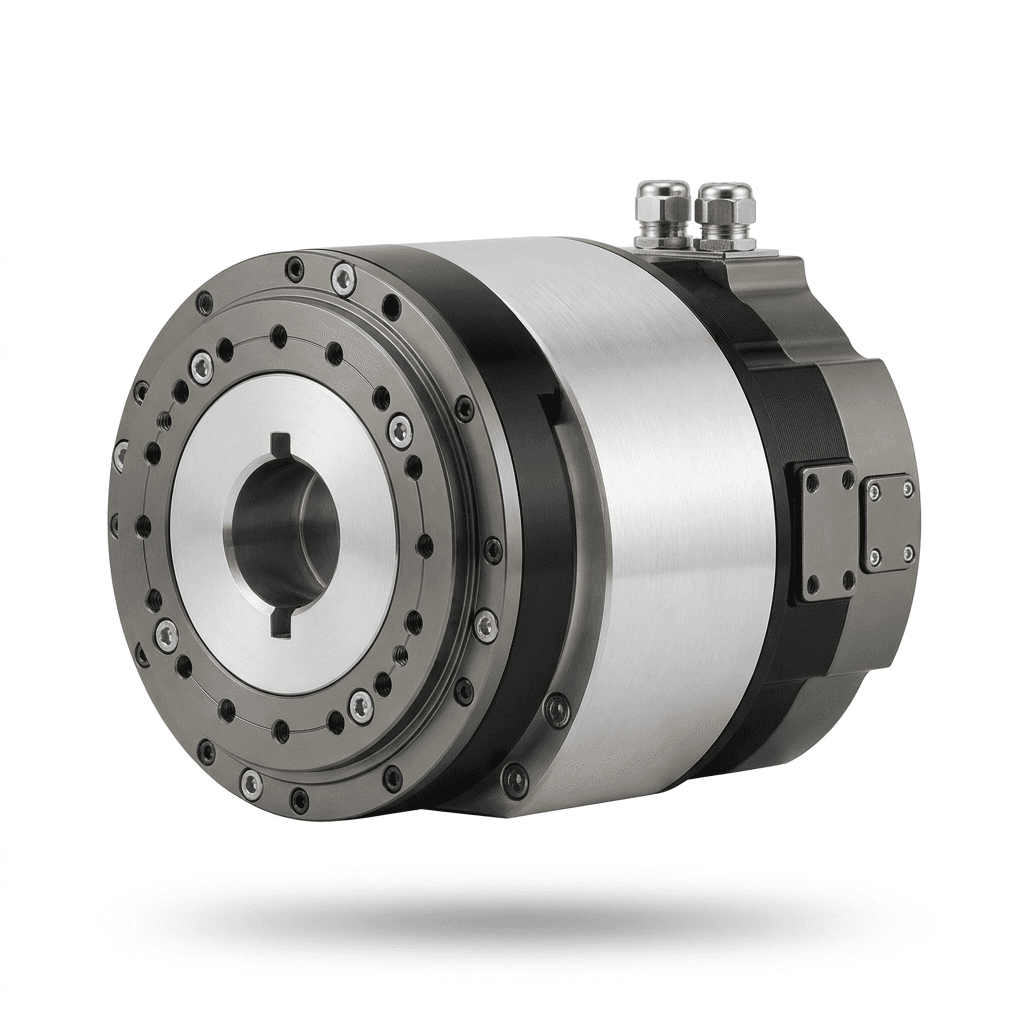
High-torque outrunner quasi-direct-drive (QDD) actuator for backdrivable robotic joints

Quasi-Direct Drive (QDD) Hollow-Shaft Actuator

Low-ratio backdrivable actuator architecture for impact-tolerant robotic joints and clean internal cable routing.

Robotics teams optimizing impact response and control transparency.

  • Sub-10:1 drivetrain strategy for high backdrivability
  • Hollow-shaft routing for cable and harness management
  • Integrated control and encoder-ready architecture
View details
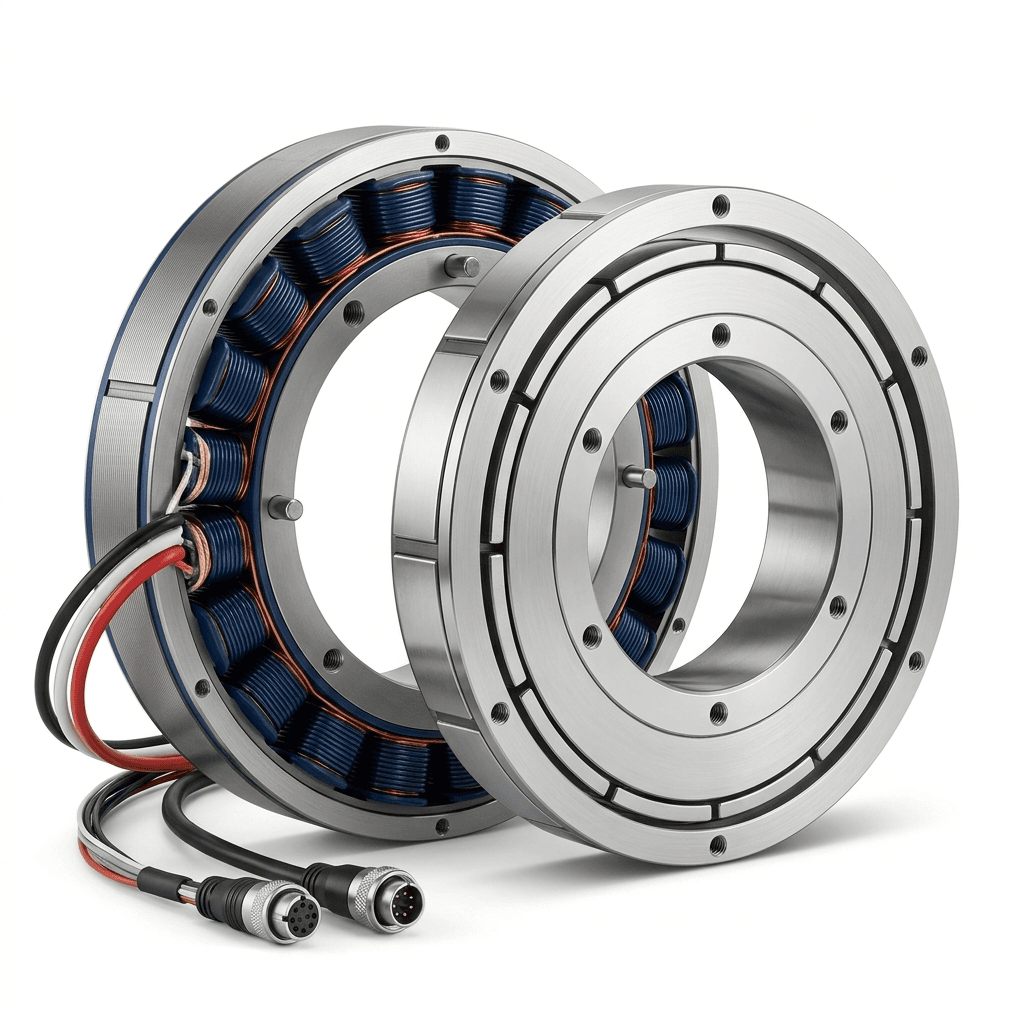
KMF direct-drive frameless torque motor stator and hollow rotor assembly

Frameless Torque Motor (Outrunner / Inrunner)

Frameless stator-rotor sets for compact direct-drive integration with low cogging and high motor constant targets.

Mechanical and motor engineers embedding drive units into custom joint structures.

  • Outrunner and inrunner options for different torque-response goals
  • Direct housing integration without bulky servo shell
  • Supports winding and KV optimization by application
View details
Torsion-spring series elastic actuator (SEA) module for compliant robotics and human interaction

Series Elastic Actuator (SEA) Module

Compliant actuation architecture for safer human-robot interaction with torque estimation and force-control readiness.

Teams requiring compliant behavior and controllable force interaction.

  • Mechanical compliance through calibrated elastic element
  • Improved impact buffering for contact-rich applications
  • Dual-feedback architecture support for force estimation
View details
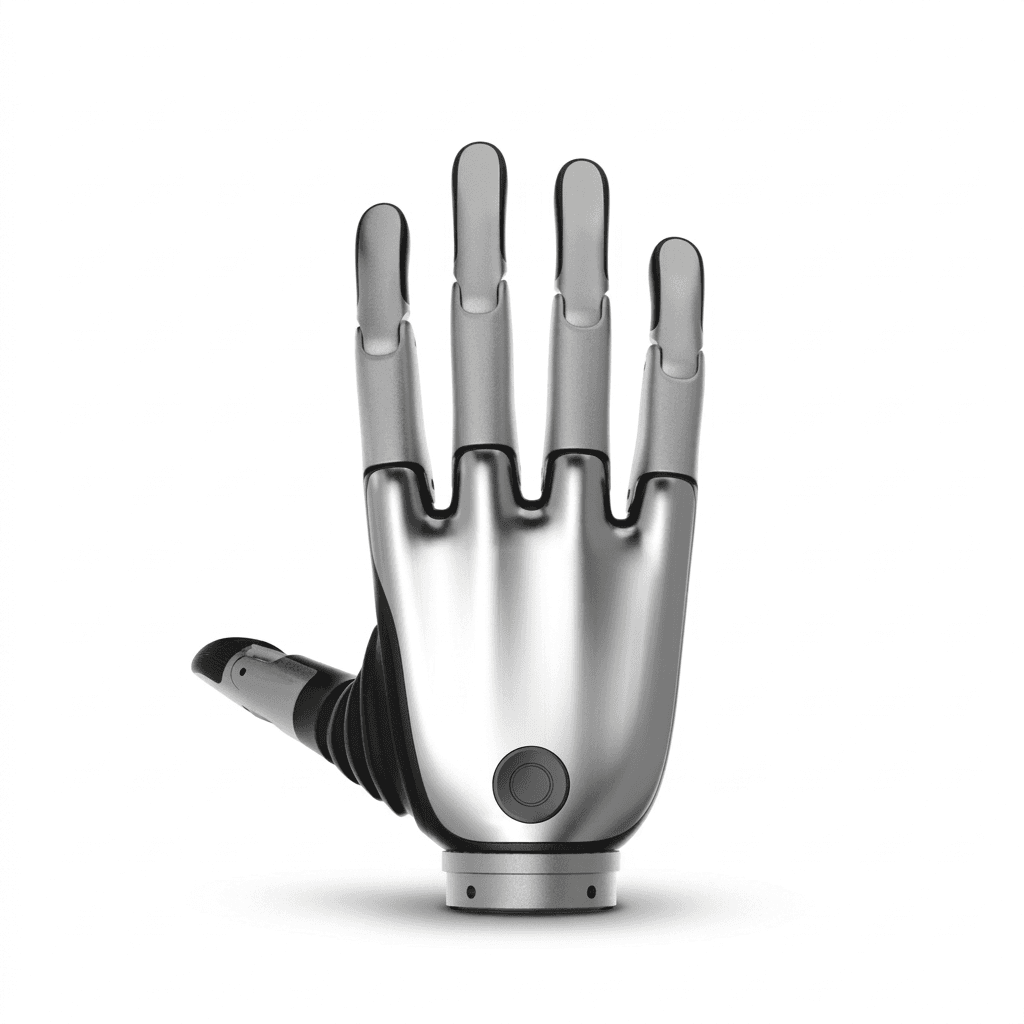
Humanoid dexterous bionic hand 5-finger articulated mechanical assembly with tactile sensors

Micro Ball Screw for Dexterous Hands

Sub-3 mm class micro linear transmission options for dexterous robotic fingers and miniature precision mechanisms.

Teams building compact, high-precision finger and miniature linear actuation systems.

  • Miniature diameter and fine lead options for compact actuators
  • Preload strategies for low backlash control
  • Consistent micro-machining quality for repeat supply
View details
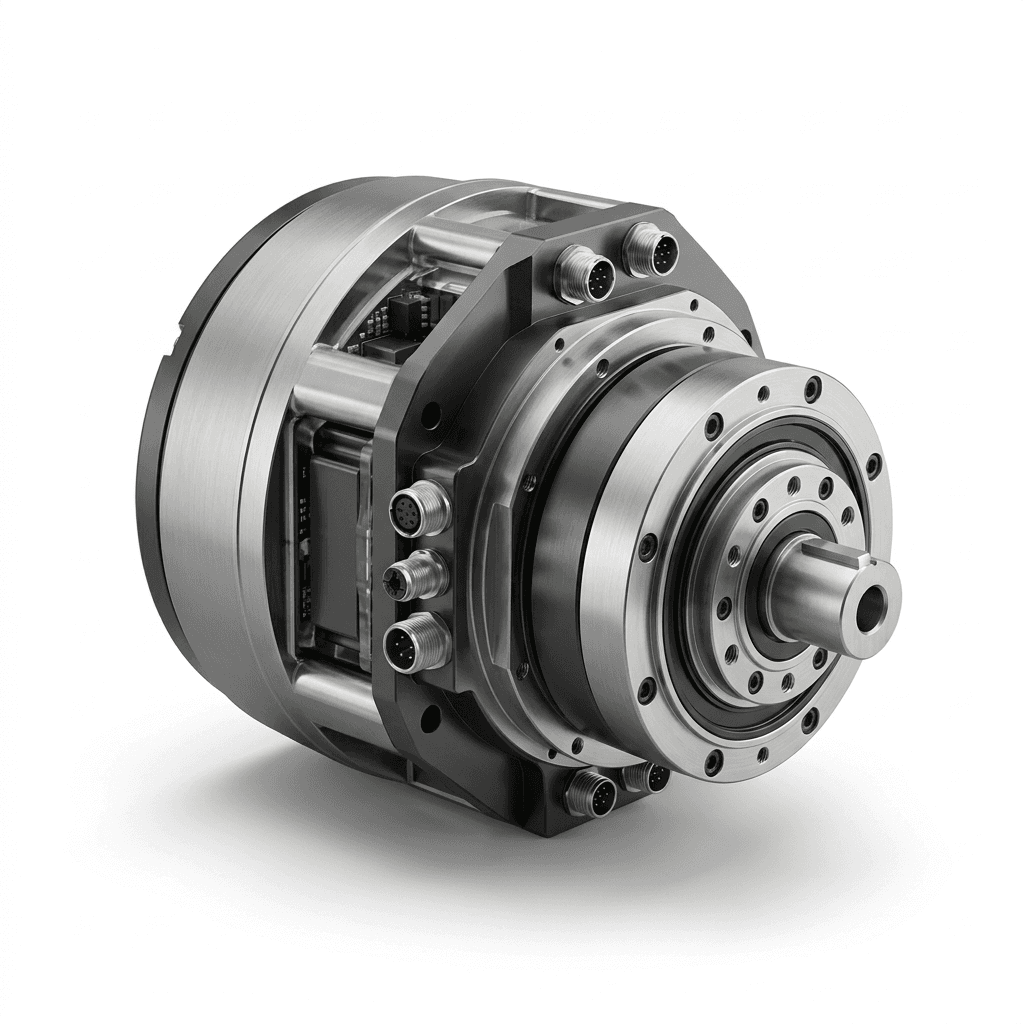
V4 precision planetary robotic joint actuator module with dual EtherCAT and CANopen fieldbus

EtherCAT / CANopen Integrated Joint Module

All-in-one rotary joint architecture integrating drive, encoder, and transmission for rapid commissioning.

Control and integration teams requiring deterministic bus-level commissioning.

  • Integrated motor, reducer, encoder, and servo drive stack
  • Supports EtherCAT and CANopen integration pathways
  • Reduces assembly complexity and commissioning timeline
View details
Cross-Family Evaluation Snapshot

Product FamilyPrimary Buyer FocusKey MetricWhy It Matters
Inverted Planetary Roller Screw ActuatorHumanoid hardware teams needing high-force linear drive in constrained envelopes.Screw diameter range: Phi 9-24 mm (project dependent)Defines axial load ceiling and packaging feasibility.
Quasi-Direct Drive (QDD) Hollow-Shaft ActuatorRobotics teams optimizing impact response and control transparency.Gear ratio: 6:1 to 10:1 typicalControls reflected inertia and impact backdrive behavior.
Frameless Torque Motor (Outrunner / Inrunner)Mechanical and motor engineers embedding drive units into custom joint structures.Stator outer diameter: 50-115 mm classesPrimary sizing input for torque constant and packaging.
Series Elastic Actuator (SEA) ModuleTeams requiring compliant behavior and controllable force interaction.Stiffness option window: 100-500 Nm/rad (project dependent)Defines system compliance and closed-loop force behavior.
Micro Ball Screw for Dexterous HandsTeams building compact, high-precision finger and miniature linear actuation systems.Diameter range: Phi 2.5-8 mmDetermines packaging feasibility in tight finger assemblies.
EtherCAT / CANopen Integrated Joint ModuleControl and integration teams requiring deterministic bus-level commissioning.Bus protocol options: EtherCAT / CANopen DS402Determines integration speed and software compatibility.

Featured Products

A selection of representative robotic joint and actuator modules from our current portfolio.

Modular collaborative robot joint actuator with dual absolute encoders
Humanoid dexterous bionic hand 5-finger articulated micro-actuator assembly
High-thrust planetary roller screw servo electric cylinder for humanoid and robotic rams
High-torque outrunner quasi-direct-drive (QDD) joint actuator for dynamic legged robotics

Inquiry Email

[email protected]

Open email app

Send target torque/speed, protocol, quantity, and delivery location.

Instant Chat

+86 18857971991

Direct response from our engineering team.